
Home / Projects / Automotive Brand Launch
A flat LED surface that becomes programmable physical depth
A kinetic LED matrix for an automotive brand launch at Beijing Shougang Park — individual modules extend and retract in time with the reveal, so the screen gains real depth instead of simulating it.
Project at a glance
- Delivered
- April 2026
- Location
- Beijing Shougang Park, China
- Setting
- Automotive brand launch
- System
- Telescopic matrix
- Motion
- Individually driven module travel
- Control
- Synchronised to show content
- Environment
- Indoor event
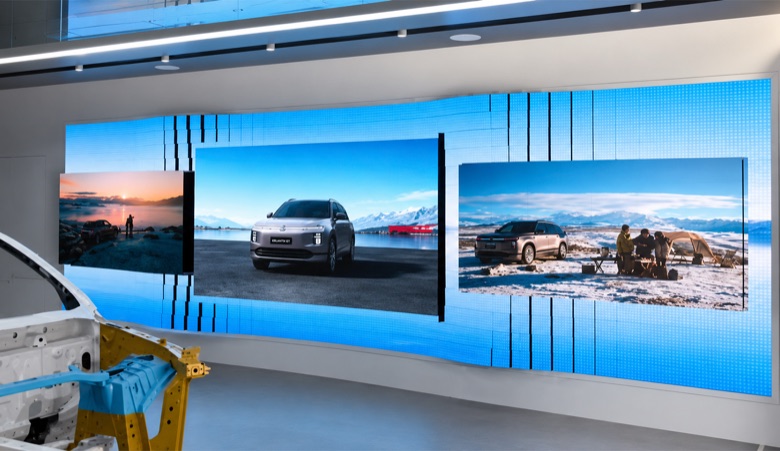
The brief: depth that is real, not rendered
Automotive launches are a saturated visual format. Every brand has an LED wall, every wall plays a film, and the audience has seen the grammar before. The request here was for a surface that could do something a flat screen cannot — change its physical shape in time with the reveal.
Video can fake depth. It cannot cast a real shadow, and it cannot make a room feel the surface move. That is the whole argument for a telescopic matrix, and it is also why the motion has to be choreographed rather than left running.
What was engineered
Module travel and pitch
Module pitch, travel distance, speed and content timing are selected together. Pick them separately and the result reads as a screen with a mechanical fault: the motion competes with the picture instead of extending it.
Individually driven modules
Each module has its own drive, which is what makes waves, relief patterns and timed extensions possible as programmed, repeatable sequences. A launch runs the same cue dozens of times in rehearsal and once when it matters — repeatability is not a nice-to-have.
Returning to a coherent surface
The hardest state is not the moving one. It is the moment the matrix has to come back flush and behave as a normal display again, cleanly, without a visible settling wobble.
Depth behind the screen
Behind-screen depth, service access, module density and support conditions decide whether the platform is viable at all in a given venue. In an event space this is usually the first constraint that bites, and it is better discovered in a drawing than on site.
| Constraint | Why it drove the design |
|---|---|
| Show timing | Motion cues built into the media sequence, not run independently |
| Behind-screen depth | Sets maximum module travel and therefore the visible effect |
| Module density | Trade-off between resolution of the relief and total drive count |
| Rehearsal load | Sequences repeat many times before the live cue — repeatability over spectacle |
Delivery
Mechanical behaviour and motion sequences are reviewed with representative content and operating states before site commissioning. For a launch there is no second night, so the rehearsal happens in the factory.
Questions this project usually raises
Why use physical depth instead of a video effect?
Video can imply depth but cannot produce it. A telescopic matrix changes the actual surface, so the relief is lit by the room’s own light and reads from any angle. It is also the one thing an audience has not already seen on every other launch screen.
How much travel is available?
Travel is set by the depth available behind the screen, together with module density and the support condition. It is a venue question as much as a product question, which is why depth and access are reviewed before the platform is fixed.
Can the matrix work as a normal flat screen?
Yes — and returning cleanly to a flush, coherent display surface is one of the harder engineering requirements, not an afterthought. Module pitch, travel and speed are chosen so the surface settles without a visible wobble.
Related
Need depth, waves or relief motion?
Share the target screen size, indoor or outdoor condition, travel expectation and service access. Engineering replies within 8 business hours.
Start engineering review